Learning the controller parameters
For each kite, but also for different wind conditions different controller settings are needed. It should be possible to determine them automatically.
The menu learning
The function menu_learning() can be used to access the following menu:
Project: hydra20_600.yml  — Choose function to execute or `q` to quit:
 > select_project()
   clear_corrections()
   train()
   plot()
   residual(full_sim=true)
   plot(full_sim=true)
   include("autopilot.jl")
   open_documentation()
   quit
Currently, it only allows to determine correction vectors for the flight path planner.
How it works:
- select the project to work with
- clear the old settings
- run the train() function, which runs up to 70 simulations to determine the optimal correction vector; it is stored in the project specific flight path planner yaml file
- plot() shows the short simulation result for the optimal parameters
- residual(full_sim=true) runs a 1000s simulation with the new parameters
- plot(full_sim=true) plots the result
- you can run the autopilot GUI with the new settings for further investigation of the result
- you can open this html documentation
- and finally quit the menu
Flight path without correction
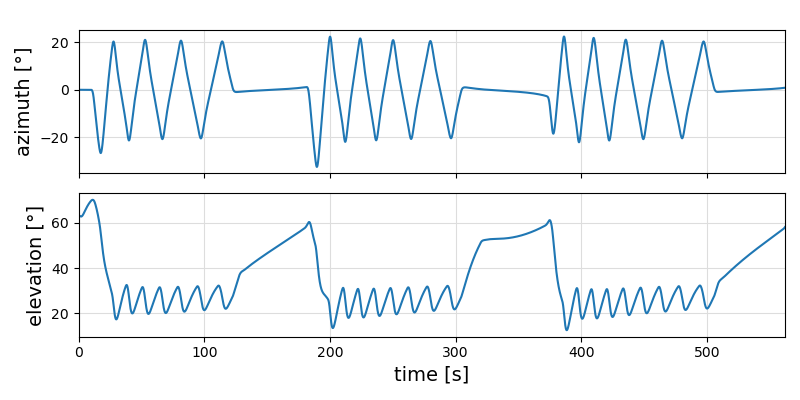
The minimal elevation angle is now 12.5 °. This is lower than intended. Intended is an elevation angle of 26 ° $\pm$ 5 ° for optimal power harvesting and safety.
Flight path with correction
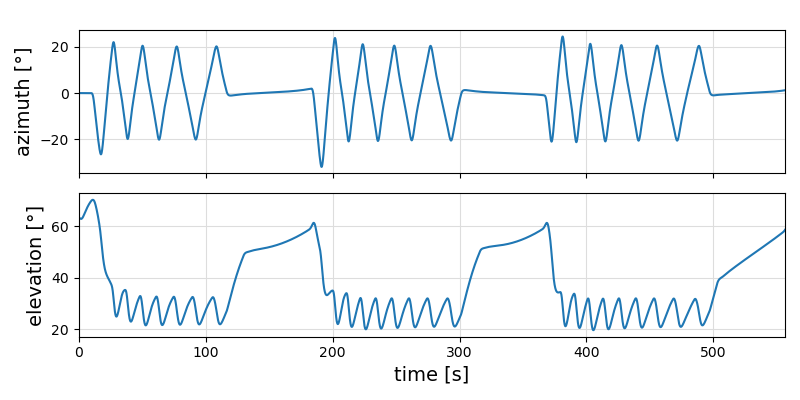
The minimal elevation angle is now 19.6 °. This increases the safety and also - a little bit - the power output, because a kite that flies too low harvests less wind energy.