Flight path controller
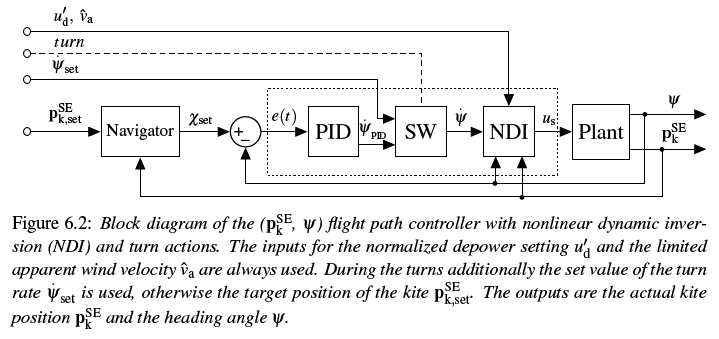
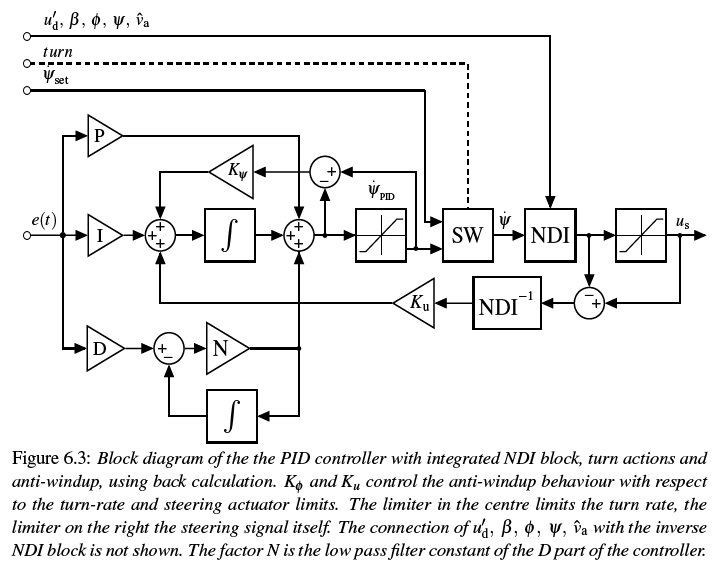
The FlightPathController is implemented as specified in chapter six of the PhD thesis of Uwe Fechner.
FlightPathController
FPCSettings
on_control_command(fpc; attractor=nothing, psi_dot_set=nothing, radius=nothing, intermediate = true)
on_est_sysstate(fpc, phi, beta, psi, chi, omega, v_a; u_d=nothing, u_d_prime=nothing)
on_timer(fpc)
calc_steering(fpc, parking)
The control commands are usually received from the FlightPathPlanner, the output of the model or the system state estimator must call on_est_sysstate each time step.